$ETH
Cooling DownSnapshot Window: 2026-09-05 07:10 UTC · ← Back to Crypto Overview
Social Momentum Summary
Total Engagement - Comments: 116, Retweets: 43, Likes: 214, Impressions: 14678
Verbatim Community Citations & Social Evidence 11 source posts analyzed
昨天市场情绪这么恐慌,比特币连77000美金都跌不破。 证明前一段时间布局进来的资金,和大机构的筹码丝毫没有任何动摇 他们在笃定清晰法案一定会通过?
$troll to $69B
Degens are degens in everychain people tried to tell you that 'RH chain community is holder, not jeeters like in Solana' Well.. same people, same mindset, same outcome RH chain-mania is about to over for short-term now either BNB or Solana season, or both
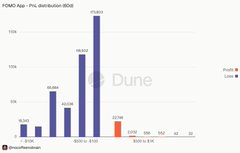
AI visual note: A bar chart titled "FOMO App - PnL distribution BNB" from Dune Analytics showing profit (purple) and loss (orange/red) distributions across different dollar ranges.
Gm, happy weekend art lovers🖤 Chromatic Armistice 5/10 0.01 on @TransientLabs 🔽
hookr is arc 2.0 only a few understand

AI visual note: A promotional poster titled 'HARMONIC LAUNCHES ON TWO VENUES' features an illustration of Aristotle writing, alongside mathematical formulas and text mentioning 'Pons' and 'Hookr v4'.
all your fav KOLs say they are waiting for a dip on $PONS for entry once it gives that entry - i wouldn't be surprised if they dont even bother talking about it anymore the edge is in being 'early' - not in waiting for a dip after the move has happened crypto narratives aren't
I love NFTs I love NFTs I love NFTs I love NFTs
One gallery 273 artists 338 artworks 291 collectors S O V R E I G N objkt.com/galleries/sovr …
Who leads next? Comment your pick $BULLA $0.073071 +142.38% $4 $0.027042 +66.27% $B $0.1957 +52.65% Register On WEEX: weex.com/events/welcome …
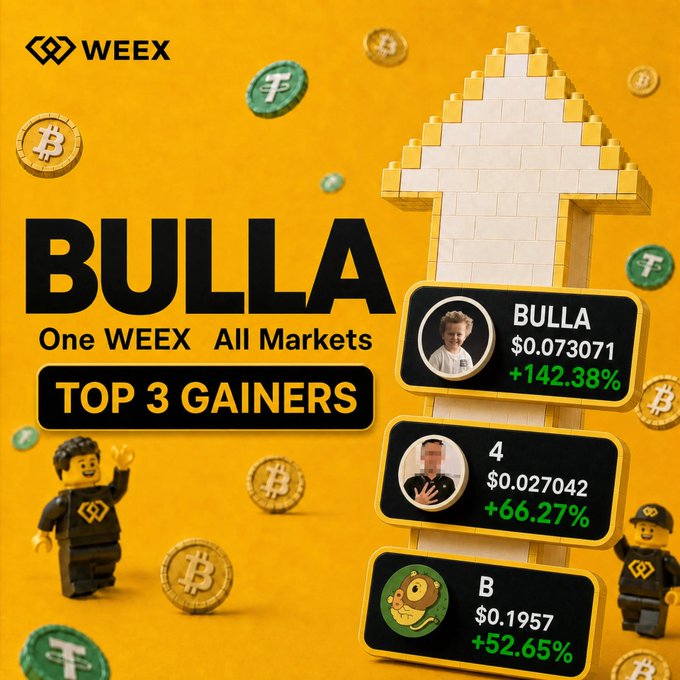
AI visual note: A promotional WEEX graphic on a yellow background features the text "BULLA — One WEEX, All Markets — TOP 3 GAINERS," highlighting BULLA at $0.073071 (+142.38%), 4 at $0.027042 (+66.27%), and B at $0.1957 (+52.65%), surrounded by crypto coins, Lego-style figures, and an upward arrow — tying directly to the post's list of top-performing tokens and its call to predict the next leader.
Elon vô tình, insider kiếm đậm, retail lại chịu trận
Seeing Is Not the Same as Doing A robot can recognize a cup, understand the instruction “pick up the cup,” and still fail to pick it up correctly. Recognition tells the robot what something is, but physical interaction requires understanding where to grip, how much force to use,
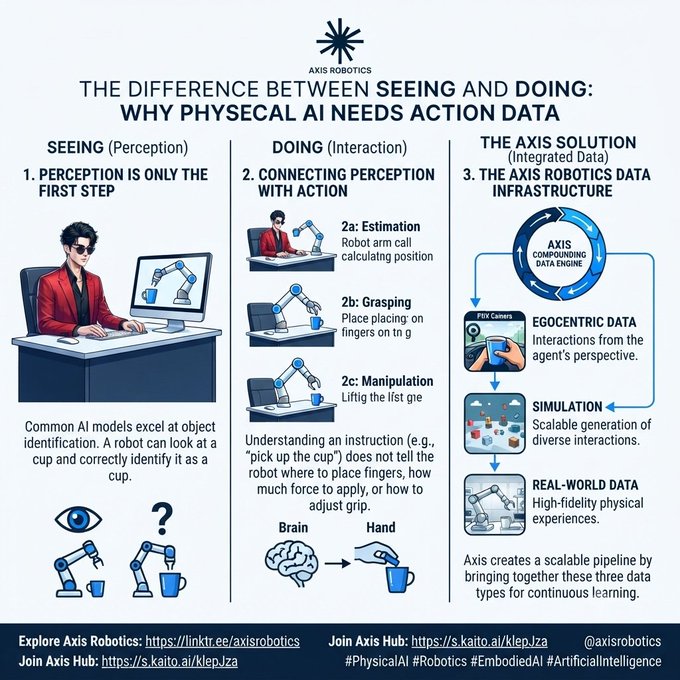
AI visual note: The infographic, titled "The Difference Between Seeing and Doing: Why Physical AI Needs Action Data" by Axis Robotics, illustrates how perception alone (identifying a cup) differs from physical interaction (grasping, manipulating), and presents Axis's solution—an integrated data infrastructure combining egocentric data, simulation, and real-world data through their Compound Data Engine. This visual supports the post's message that recognizing objects is insufficient for robots to actually perform physical tasks like picking up a cup.